Robotics lead
I have worked with VEX V5 software, robot design, and technical reviews while helping Garces Robotics grow from two teams and about 12 students to four teams and 24 members.

yo wsp, i'm
I'm a teen software engineer passionate about hacking the world around us. I'm currently focused on Hack Club, programming for my school's robotics team, and experimenting with side projects.
Current engineering roles
I am a student at Garces Memorial High School, President and Treasurer of Garces Robotics, Vice President of Garces Chess Club, captain of V5RC 28002A for the 2026–2027 Override season, and Garces 3D printing officer. I also serve in Civil Air Patrol as a C/Amn.
I have worked with VEX V5 software, robot design, and technical reviews while helping Garces Robotics grow from two teams and about 12 students to four teams and 24 members.
About two years using Autodesk Inventor plus Fusion 360. I design brackets and assemblies, then iterate from measured fit and load problems.
I manage 3D printing at Garces and use Bambu Studio and OrcaSlicer for slicing, print setup, troubleshooting, and repeatable fabrication.
I work across Rust, C/C++, TypeScript, Next.js, embedded devices, ML experiments, Linux, and NixOS. Public repos show the implementation.
I have been passionate about engineering ever since I was about seven. I found a laptop nearly as old as me running my old home's security system. After we moved, it had no real purpose, so I took it for my own use. I started with web development and made a collection of small projects by following tutorials. This was probably the most impactful experience I ever had: I found joy in building things. It strongly connects to my interest in engineering. I wanted to expand my design skills instead of only copying stuff.
Engineering is just so freaking cool. The satisfaction I get from solving problems is like no other, especially because I get to work with a lot of cool tools along the way.
In my studies, I hope to improve my knowledge of mechanical systems and get more experience at being a good engineer. I want to be more studious and particular with notes, the design process, and journaling. I believe the process is a bigger part of a project than the result.
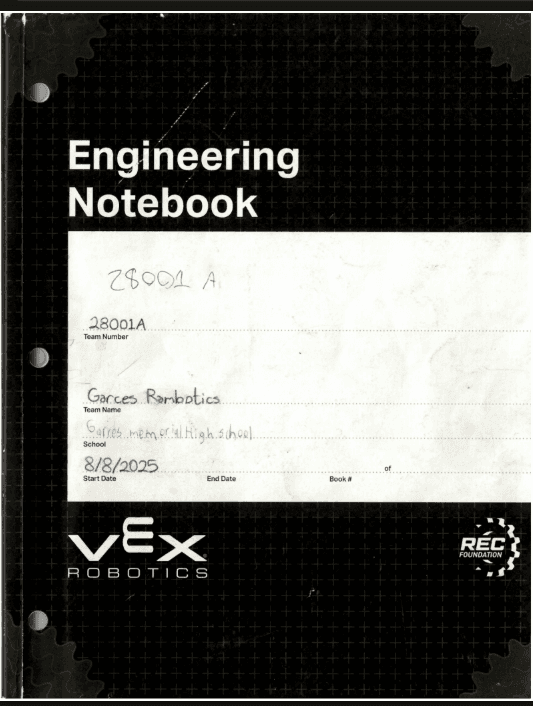
I hope to build something that solves a real problem in my life. I would be happy with pretty much anything difficult. The notebook beside this is from my work with V5RC 28001A.
Robotics has also shown me that I learn better when I teach. I helped our program grow from two teams and about 12 students to four teams and 24 members, which meant spending more time explaining mechanisms, debugging with newer builders, and making room for other people to try things themselves. Helping can take time away from my own work, but it also forces me to understand why something works instead of only knowing that it works.
After I graduate high school, I would like to attend a top engineering school. I am particularly invested in MIT, although the exact school matters less to me than getting to do difficult, meaningful engineering work. I would like to study mechatronics so I can keep mechanical design, electronics, controls, and software in the same field.
With a degree, I would look at defense-contractor work, an Air Force engineering pathway, private industry, or a research-focused government role such as NASA. My experience as a C/Amn in Civil Air Patrol is part of why aviation and service both interest me.
I would also love to work on cutting-edge AI research at a lab such as OpenAI, NVIDIA, or Anthropic. Disregarding all of that, I would love to start my own business, build a product people want, and live off it.
After high school, I see myself working in an engineering role at minimum for a first job, or putting more time into my studies. With my current experience, I want to be ready for early engineering work or self-employment instead of waiting for a degree to begin building.
STARDANCE 2026 · SUPER STAR
I turned a rolling classroom chair into a VEX V5 vehicle. I started by measuring the angled seat base, replacing an early bent-metal mount with a CAD-designed and 3D-printed bracket, then building the frame from VEX C-channel. The drivetrain uses four 200 RPM motors per side and a 72:48 gear ratio. My initial calculation estimated 24.8 lbf of pushing force.
The latest logs close out both the hardware and software. Three V5 Brains now communicate through a framed serial protocol with startup handshakes, left/right assignment, health packets, retries, timeouts, and fault recovery. A rotation sensor replaced the broken throttle potentiometer; the controls now support calibrated forward/reverse input, normal turns, turns in place, and tuned steering feedback.
The chair now drives reliably with a rider. Its displays report motor temperatures, faults, battery and link state, control positions, and communication diagnostics without blocking the control loop. Startup, parked, armed, and fault states keep the system predictable, with a restart-only E-STOP. One intermittent power-sharing issue remains under observation after low, mismatched batteries caused a Brain to shut down during testing.
STARDANCE 2026 · 4 DEVLOGS · 12H
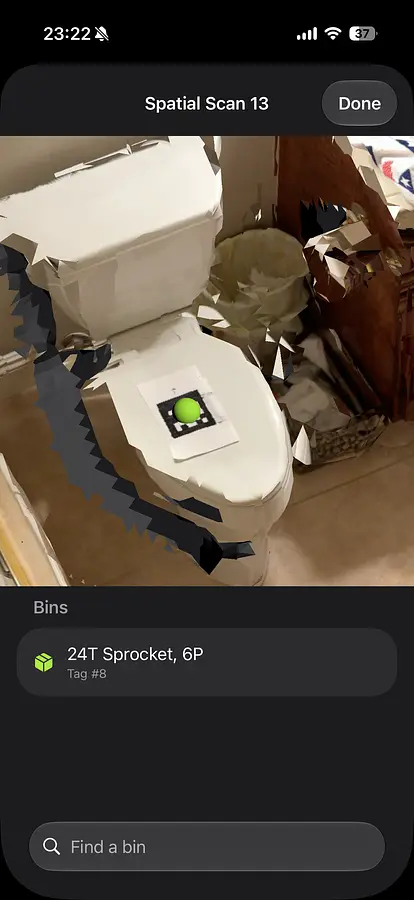
I built an ML-assisted VEX V5 parts identification and inventory system. Goal: point a phone at stored parts, identify them, and attach useful inventory tags without entering every variation by hand.
The newest build fuses filtered LiDAR depth with the AR mesh, welds seams, removes bad geometry, preserves corners, repairs small holes, and rejects blurry frames. AprilTags lock after repeated viewpoints and mesh raycasts, while the scanner shows live depth, mapped surfaces, coverage, range, tracking quality, and lock progress.
I also built a Metal backend for AprilTag detection after studying NVIDIA shaders and the C++ implementation. GPU detection raises frame rate and improves tag placement during 3D scans, with a CPU fallback. Photo and scan workflows now share an Area model, and the viewer gained highlighting and better camera controls.
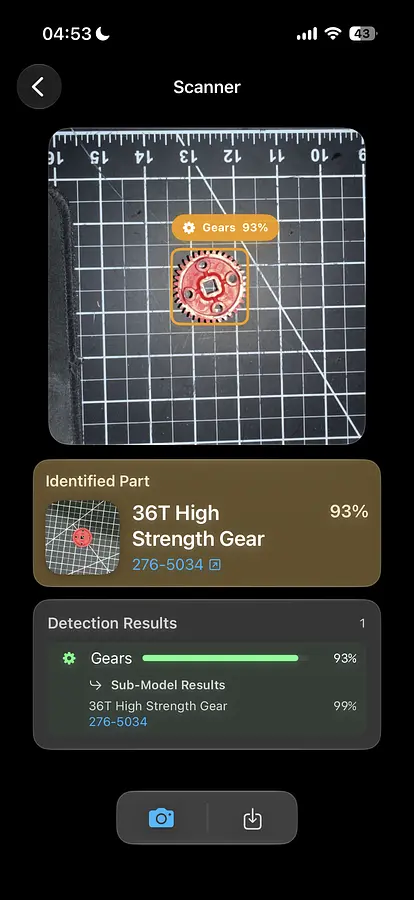
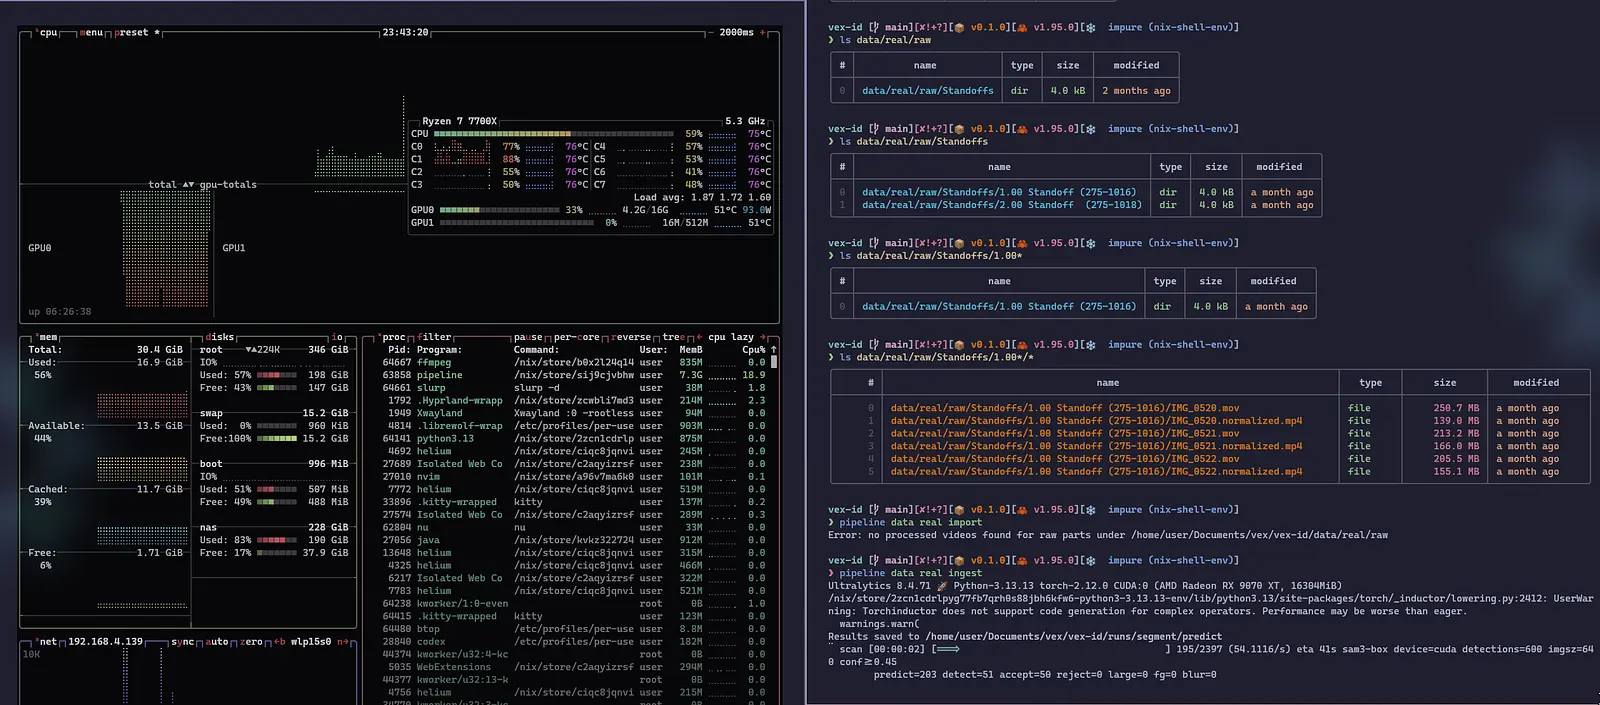
Robotics responsibility
2025–2026
I programmed and helped design the competition robot in Rust with vexide. I also built an autonomous-route recorder and learned, through broken chains, rubber bands, and seized motors, that reliable software still depends on the entire machine.
Team record2026–2027 · Override
I have worked with the team on technical planning, robot software, design review, build coordination, and documentation. I learn better when I teach, so helping newer members understand why a mechanism works is part of how I improve my own engineering.
Current team recordGarces Robotics
I helped expand the program from two teams and about 12 students to four teams and 24 members. I now help organize the people, budget, equipment, and technical support needed to give more students room to build and learn.
Robotics organizationGarces Memorial
Manage slicing, printer setup, troubleshooting, and part production. Current tools include Autodesk Inventor, Fusion 360, Bambu Studio, and OrcaSlicer.
Engineering pathway1st place in Cognitive Science, Junior Division, for "Unraveling AI," a project about AI detection and how easily humans can be fooled by AI-written essays.
Four public projects and 18 devlogs. The Chair alone records 34 hours across CAD, fabrication, three-Brain networking, controls, safety, telemetry, and ride testing.
11 answers, 6 questions, and 104k people reached. This is older work, but it documents years of debugging in public.
1st place in Cognitive Science before state, then advanced from the California fair to nationals.
8 shipped projects, 107 devlogs, and 490h 31m logged. The record covers model training, reproducible builds, streaming parsers, performance work, and production debugging.
Four merged pull requests: devlog API routing and views, pagination fixes, API rate-limit work, and a vector project icon. I also maintain a Catppuccin userstyle.
Robotics, Mechatronics & Software Engineering
Bakersfield, Californiaeli.bestgithub.com/elijah629Stardance build logsV5RC 28002A
Student engineer with experience in competitive robotics, CAD, additive manufacturing, embedded systems, Rust, TypeScript, and machine learning. I have worked with VEX V5 systems from design and programming through fabrication, testing, and technical documentation.
Robotics & hardware: VEX V5 · vexide · controls · mechanism design · prototyping · embedded systems
CAD & fabrication: Autodesk Inventor · Fusion 360 · 3D modeling · Bambu Studio · OrcaSlicer · 3D printing
Software: Rust · C/C++ · TypeScript · Next.js · React · Python · NixOS · Git
Engineering Experience
Built a rideable VEX V5 chair with an eight-motor differential drivetrain, custom CAD/3D-printed mounts, three-Brain serial networking, calibrated rotation-sensor throttle and steering, live diagnostics, and fault-safe controls. Reached reliable rider testing across 12 public devlogs and 34 logged hours.
ML-assisted VEX V5 parts identification system documented across 4 devlogs and 12 logged hours. Fused LiDAR depth with repaired AR meshes, locked AprilTags through multi-view mesh raycasts, and built a Metal GPU backend for faster detection with a CPU fallback.
Built a compact feature-based AI text detector in Rust, made training reproducible with seeded randomness, automated data download and model rebuilds, compiled inference to WASM, and published the crate.
Four merged pull requests covering devlog API routes and views, pagination fixes, API rate limits, and vector icon work; also built and maintains a Catppuccin userstyle.
Education & Recognition
Class of 2029 · Bakersfield, California
Engineering, robotics, CAD, fabrication, computer science, and technical documentation.